Matek F405-WMO Fixed-Wing Flight Controller
Technical Highlights
Compact Fixed-Wing Control
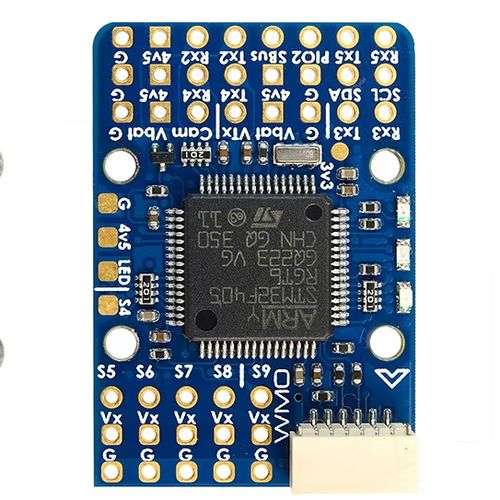
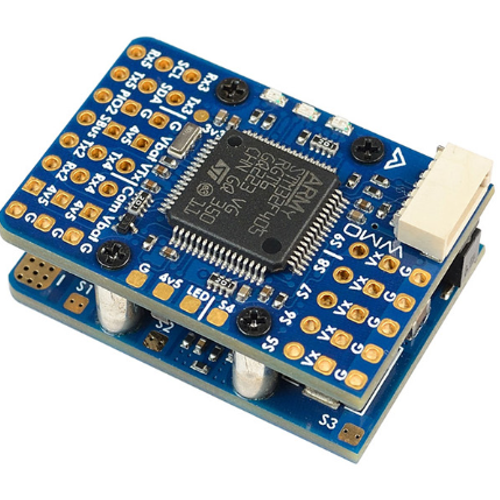
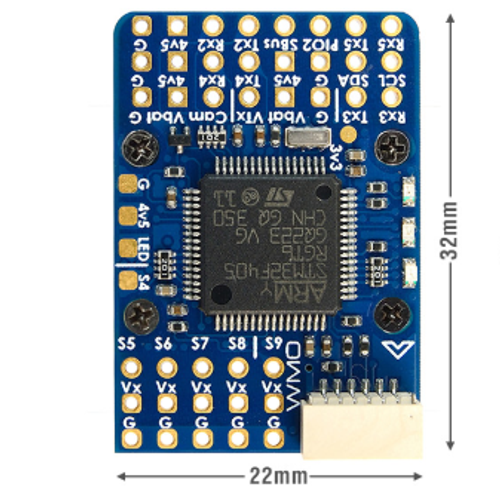
The F405-WMO uses an STM32F405RGT6 MCU and an ICM42688-P IMU in a 32 × 22 × 12.7 mm assembly. Matek specifies a weight of 9 g.
Onboard Sensors and SD Logging
An SPL06-001 barometer and AT7456E OSD chip are integrated on the board. A dedicated SD card slot provides storage for flight logs.
Power Outputs for Airframe Integration
The board accepts 5.4–30 V DC input. It provides a 5 V output rated at 2 A and a servo Vx output rated at 4.5 A continuous, with a stated 7 A peak. Vx is 5 V by default, with a 6 V option.
Fixed-Wing Interfaces
Matek documents four UARTs, one I2C bus, nine S1–S9 outputs and an LED PWM output. Filtered battery-voltage output for an external camera or video transmitter can be switched on or off.
Technical Specifications
| Model | F405-WMO |
|---|---|
| MCU | STM32F405RGT6, 168 MHz, 1 MB flash |
| Gyroscope | ICM42688-P |
| Barometer | SPL06-001 |
| OSD Chip | AT7456E |
| Blackbox Storage | SD card slot |
| Serial Interfaces | 4 UARTs |
| I2C | 1 bus |
| Outputs | S1–S9 plus LED PWM output |
| Input Voltage | 5.4–30 V DC (2–6S LiPo) |
| 5 V Output | 2 A |
| Servo Vx Output | 5 V default or 6 V option; 4.5 A continuous, 7 A peak |
| Dimensions | 32 × 22 × 12.7 mm |
| Weight | 9 g |
Firmware and Current-Sensor Selection
Use the manufacturer-listed MATEKF405TE_SD target for INAV or MatekF405-TE for ArduPilot. Do not assume that a target for another Matek F405 model applies to the F405-WMO.
For ArduPilot SD-card logging, Matek specifies LOG_BACKEND_TYPE = 1 (File).
Check the current-sense resistor marking on the delivered PDB. Matek reports that a PDB marked “3m0” has a 13.2 A sensor range rather than the 132 A range in the main specification.
Confirm the Vx voltage setting and the power requirements of connected servos before applying power.
Remove propellers before configuration or output testing.
FAQ
Which firmware targets are listed for the F405-WMO?
Matek lists MATEKF405TE_SD for INAV and MatekF405-TE for ArduPilot.
Does the F405-WMO use onboard flash for blackbox logging?
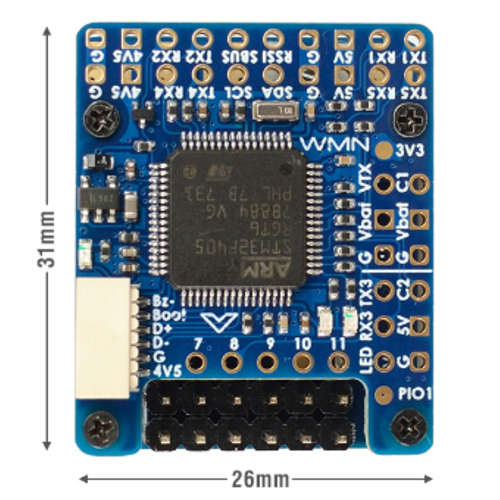
No. The F405-WMO has an SD card slot. The 16M-flash specification shown for the F405-WMN comparison model does not apply to the F405-WMO.
What is the servo Vx output?
Vx is 5 V by default and has a 6 V option. Matek rates it at 4.5 A continuous and 7 A peak.
Why must the PDB current-sense resistor be checked?
Matek reports that some PDBs were fitted with a “3m0” resistor. Those units have a 13.2 A current-sensor range instead of the 132 A range stated for the corrected version.
B2B Procurement FAQ
How can the required PDB revision be specified?
Request confirmation of the shunt-resistor marking and the current-sensor range for the exact units being quoted.
Are the USB/beeper extender and cable included?
Matek lists these items in its manufacturer package description, but the contents of the specific offer should be confirmed during quotation.
What are the MOQ and lead time?
MOQ, available quantity and lead time must be confirmed during quotation.
Leave Your Message
Products categories
-
ZMR NX4 EVO Fixed-Wing Gyro Flight Contr
-
ZMR NX4 PRO Fixed-Wing Gyro Flight Contr
-
CUAV X7+ Pro Autopilot Flight Controller
-
RadioLink F722 Betaflight Flight Control
-
SpeedyBee F405 V5 OX32 55A FPV Stack
-
SpeedyBee F405 V4 BLS 60A FPV Stack
-
SoloGood F722 V1.0 60A FPV Stack
-
SIYI N7 H7 Autopilot Flight Controller
-
SpeedyBee F7 Mini 35A BLHeli_S Stack
-
RadioLink CrossFlight V1.0 Flight Contro