Holybro Pixhawk 6X (Rev 8, ICM-45686) Flight Controller
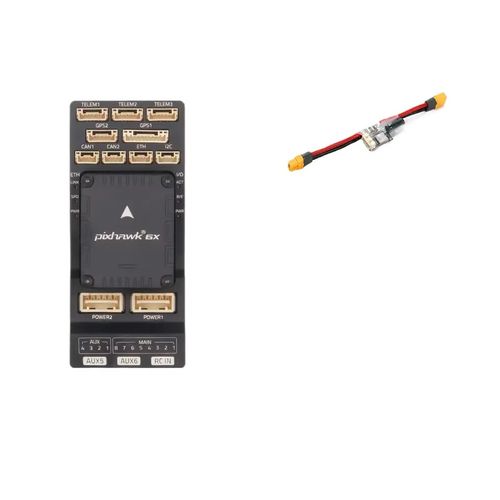
Technical Highlights
Triple ICM-45686 IMU Architecture
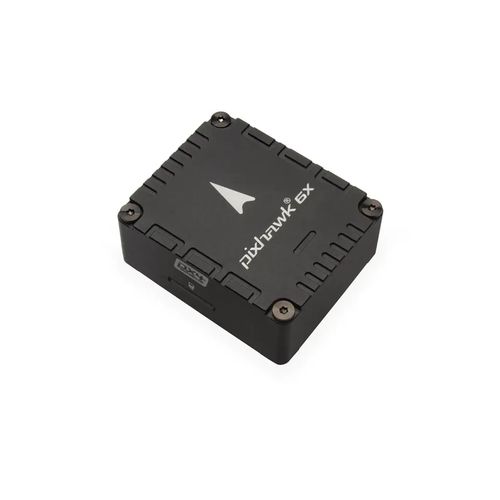
The Rev 8 Pixhawk 6X uses three ICM-45686 inertial sensors with BalancedGyro technology. Its modular architecture separates the IMU, flight-management and baseboard systems.
STM32H753 Flight-Management Processor
The 32-bit STM32H753 FMU runs at up to 480 MHz. An STM32F103 processor handles I/O functions.
Selectable Baseboard Layout
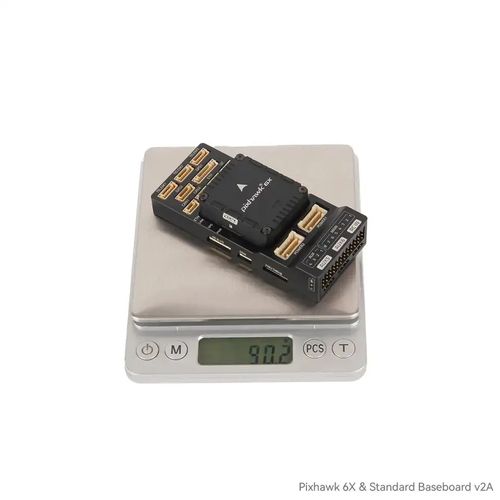
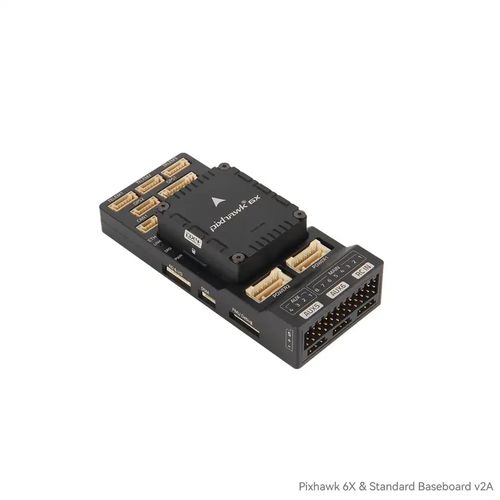
Choose a Standard v2A, Standard v2B or Mini baseboard to suit the installation layout. The Standard v2A and v2B share the same port pinout; their header-pin orientation differs.
PX4 and ArduPilot Support
The controller ships with PX4 firmware. The ICM-45686 Rev 8 hardware is supported by PX4 1.14.3 or later and ArduPilot 4.5.0 stable or later.
Flight Controller Specifications
| Hardware Revision | Pixhawk 6X Rev 8 with ICM-45686 sensors |
|---|---|
| FMU Processor | STM32H753, 32-bit Arm Cortex-M7, up to 480 MHz |
| I/O Processor | STM32F103 |
| Inertial Sensors | 3 × ICM-45686 IMUs |
| Barometers | ICP20100 plus BMP388, BMP580 or BMP581, depending on production revision |
| Onboard Magnetometer | BMM150 |
| Firmware Targets | PX4 FMUv6X; ArduPilot Pixhawk 6X |
Configuration Selection
| Standard v2A | Standard baseboard with one header-pin orientation. The supplied images show kits with M9N GPS, M10 GPS and no GPS. |
|---|---|
| Standard v2B | Standard baseboard with the alternate header-pin orientation and the same port pinout as v2A. The supplied images show kits with M9N GPS, M10 GPS and no GPS. |
| Mini | Compact baseboard. The supplied images show M9N GPS, M10 GPS and no-GPS kit configurations. |
| FC Module Only | Pixhawk 6X flight controller module without a baseboard or GPS module. |
Integration Notes
Select the baseboard and GPS configuration before ordering; accessories shown across different images do not all belong to one kit.
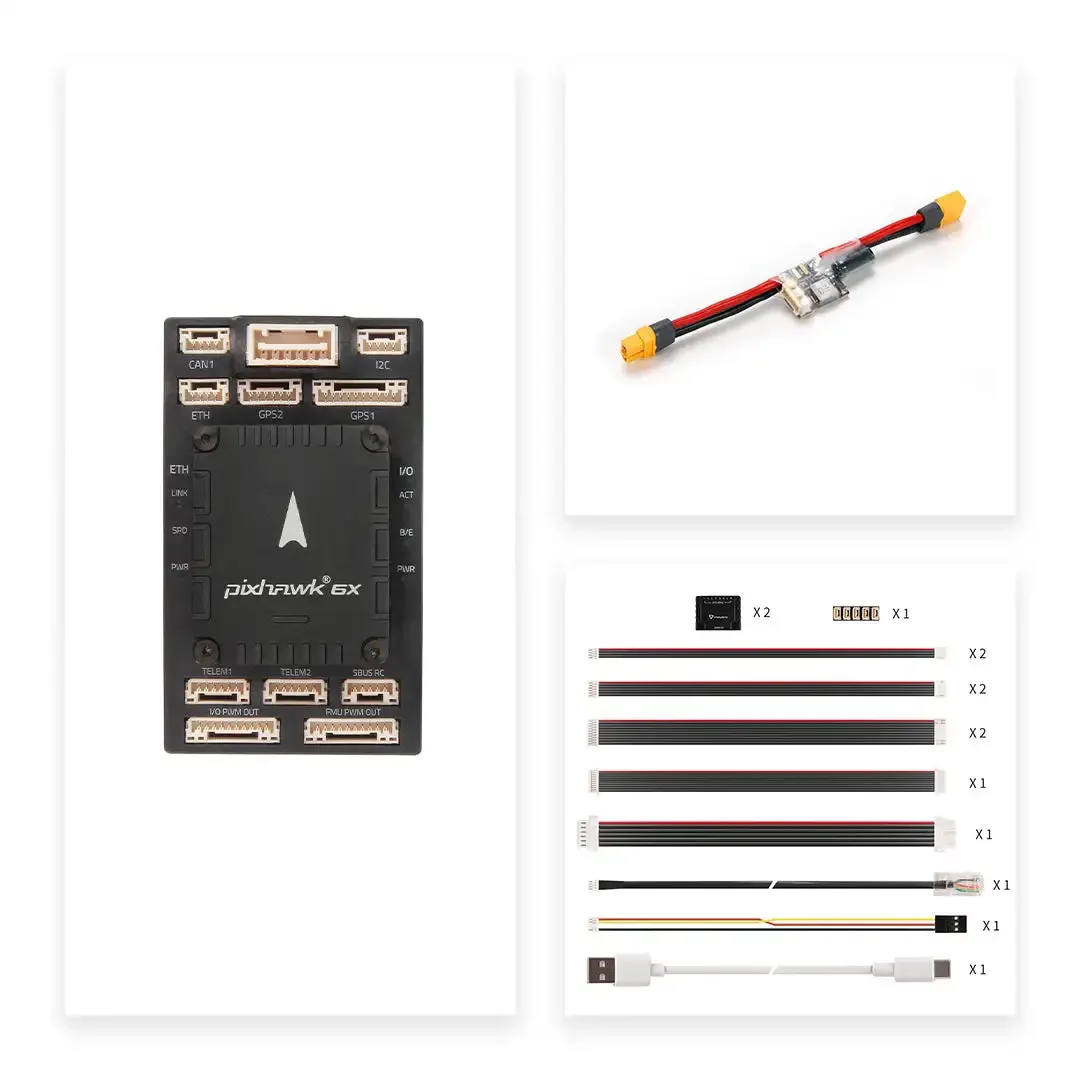
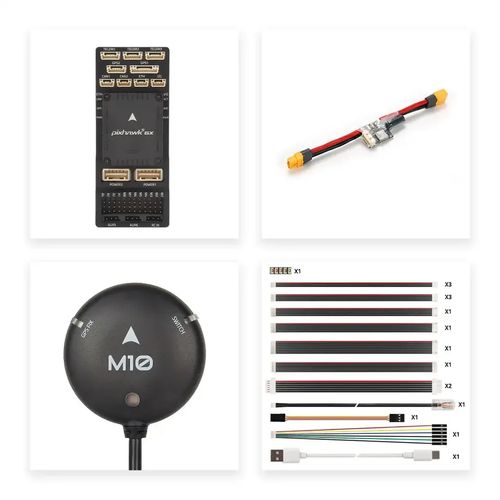
Baseboard kits shown in the supplied images include a power module and cable set. Confirm the exact contents of the chosen SKU.
Holybro specifies a compatible digital power module, such as the PM02D, for Pixhawk 6X power monitoring.
Use the Rev 8 firmware target and a supported firmware release when installing or updating the controller.
FAQ
Is this the Pixhawk 6X Pro?
No. This listing is for the Pixhawk 6X Rev 8 with three ICM-45686 IMUs, not the Pixhawk 6X Pro.
Does every configuration include a GPS module?
No. The supplied images show M9N GPS, M10 GPS and no-GPS configurations, as well as an FC-module-only option. Check the selected kit before ordering.
What is the difference between Standard v2A and Standard v2B?
Holybro states that their ports and pinout are identical. The header pins face different directions, so choose according to the intended wiring layout.
Which firmware should be used with the ICM-45686 revision?
The Rev 8 controller supports PX4 1.14.3 or later and ArduPilot 4.5.0 stable or later. Its targets are PX4 FMUv6X and ArduPilot Pixhawk 6X.
Why can the barometer part number vary?
The supplied product graphic identifies ICP20100 and BMP388. Holybro's current specification also lists BMP580 or BMP581 as possible second-barometer parts, depending on production revision.
B2B Procurement FAQ
What configuration details should be included in an RFQ?
Specify the Pixhawk 6X ICM-45686 revision, Standard v2A, Standard v2B, Mini or FC-only configuration, and whether M9N GPS, M10 GPS or no GPS is required.
Can the exact barometer revision be specified?
State the required barometer part number in the RFQ. The component fitted to the quoted production batch must be confirmed before purchase.
Are the power module and cables included?
They are shown with the pictured baseboard kits, but not with the FC-module-only option. Request a kit-specific packing list during quotation.
What are the MOQ, lead time and warranty terms?
These terms are not established by the supplied product materials and must be confirmed during quotation for the selected configuration.
Leave Your Message
Products categories
-
ZMR NX4 EVO Fixed-Wing Gyro Flight Contr
-
ZMR NX4 PRO Fixed-Wing Gyro Flight Contr
-
CUAV X7+ Pro Autopilot Flight Controller
-
RadioLink F722 Betaflight Flight Control
-
SpeedyBee F405 V5 OX32 55A FPV Stack
-
SpeedyBee F405 V4 BLS 60A FPV Stack
-
SoloGood F722 V1.0 60A FPV Stack
-
SIYI N7 H7 Autopilot Flight Controller
-
SpeedyBee F7 Mini 35A BLHeli_S Stack
-
RadioLink CrossFlight V1.0 Flight Contro